

Tool for segmentation-based deformable registration and object matching
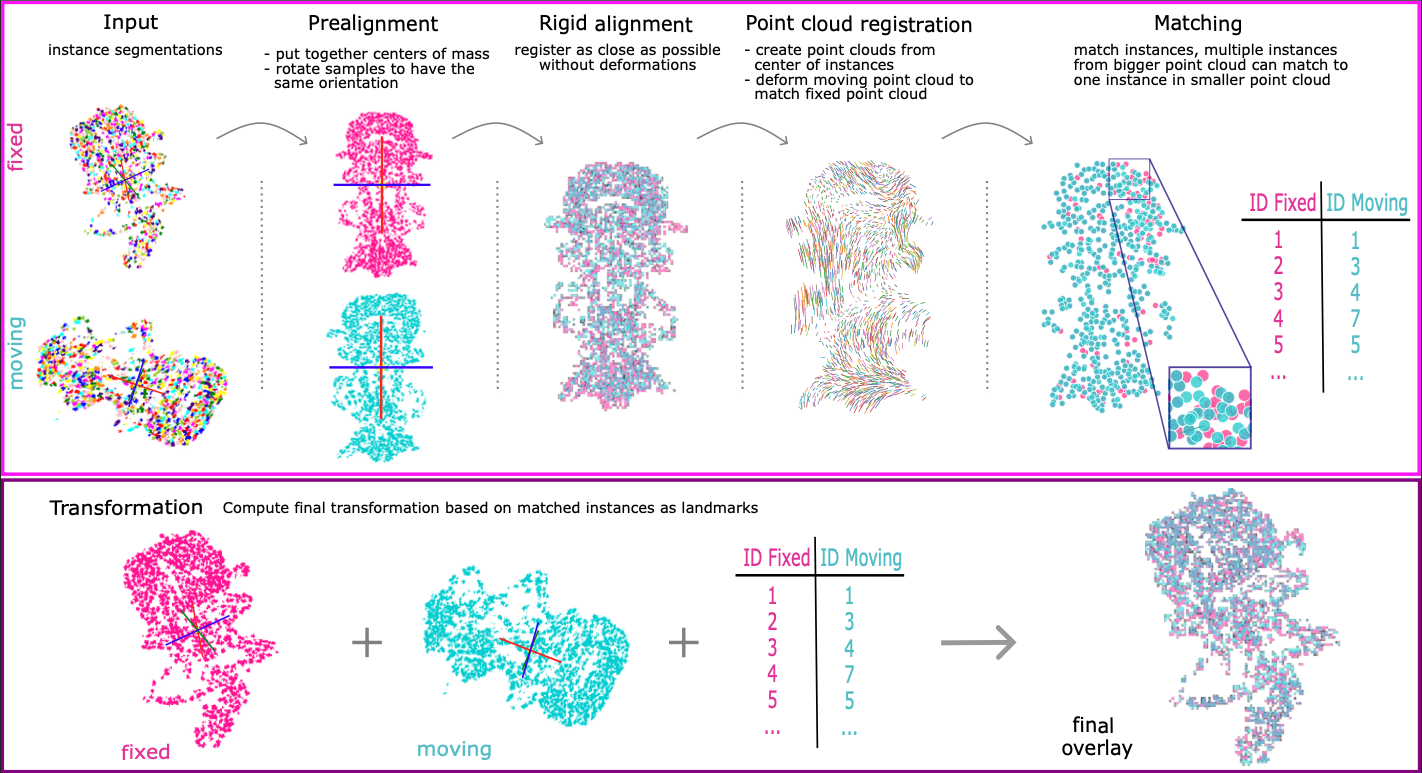
Image-Matchmaker is a framework that leverages instance segmentation masks to align two volumetric datasets of e.g. different modalities like EM and LM. It optimizes a transformation that maps a moving volume onto a fixed reference volume, progressively refining the spatial correspondence through a sequential pipeline:
- Pre-alignment (SVD) — coarse global alignment of centroids and principal axes.
- Rigid registration (Elastix) — rotation + translation refinement.
- Coherent Point Drift (CPD) — non-rigid alignment of instance-centroid point clouds.
- Instance matching — establish instance correspondences.
- B-spline registration (Elastix) — final deformable alignment driven by the matched landmarks on the original masks (rigid → rough → fine B-spline).
The composed rigid + B-spline transform can then be reapplied to the raw channels of the original volumes (e.g. raw EM or fluorescence LM) to bring them into a shared coordinate space.
For a standard installation, install Image-Matchmaker with pip:
pip install image-matchmakerFor development, clone the repository and follow the Installation Guide to set up the environment.
Run the registration workflow using a configuration file:
image-matchmaker register --config /path/to/config.yaml --cores 8To apply the resulting transform to other images:
image-matchmaker apply --config /path/to/config.yaml --cores 8The --config option is required. See the Quick Start and Configuration Reference for details.
Full documentation is available at https://image-matchmaker.readthedocs.io/, including:
- Installation — install via pip or from source.
- Quickstart — run your first registration.
- Usage — CLI workflow, individual scripts, and Python API.
- Configuration reference — registration and transform parameters.
- Outputs — files produced by each stage.
- Troubleshooting — common issues and solutions.