
From images to 3D Gaussian scenes
Feed-forward 3DGS reconstruction for novel-view rendering, from single view reconstruction (v1) to multi-view reconstruction (v2 & v3).
| SplatAnything (InfiniSplat v3) · Any Views & Scales | InfiniSplat v2 · Any Views | InfiniSplat v1 · Single View | |
|---|---|---|---|
| Input | Arbitrary number of images across arbitrary scene scales, with or without camera poses | Arbitrary number of images, with or without camera poses | One RGB image, optionally guided by LiDAR depth |
| Explore | Code and usage ·Live demo | Code and usage · Live demo | Code and usage · Live demo |
🌐 SplatAnything (InfiniSplat v3): Gaussian Spacing Normalization
for Feed-Forward 3DGS across Arbitrary Scenes


Hao Yu1,2 ·
Zhenwei Wang2 ·
Yongzhen Hu1 ·
Yuning Gong2 · Junta Wu2
Xiaowei Zhou1 ·
Hujun Bao1 ·
Tengfei Wang2,† ·
Chunchao Guo2,† ·
Sida Peng1,3
1 Zhejiang University · 2 Tencent Hunyuan · 3 Causa Robotics
† Corresponding authors.
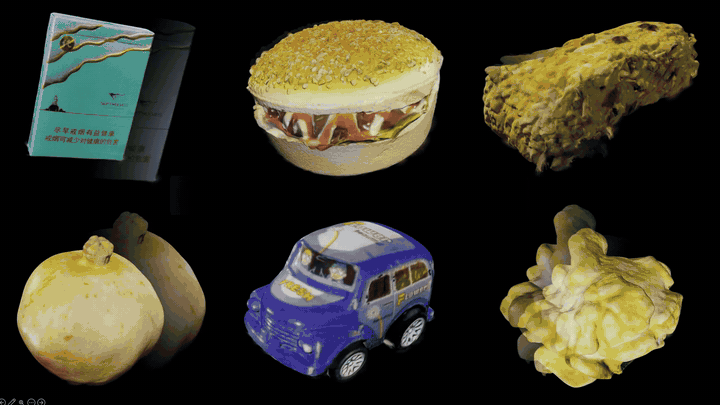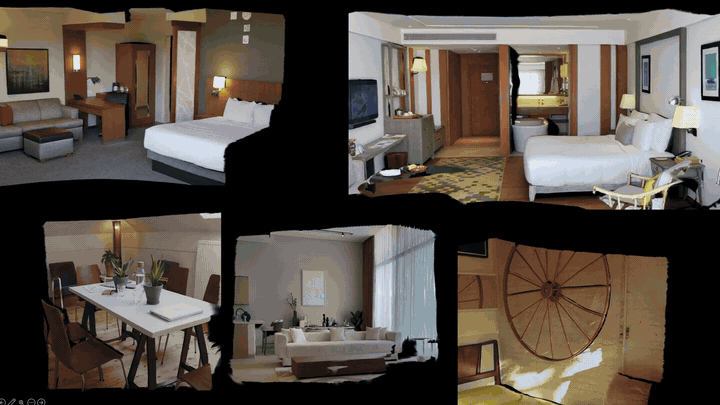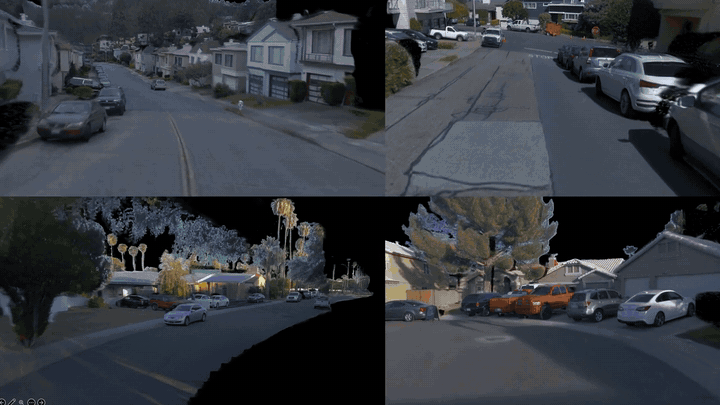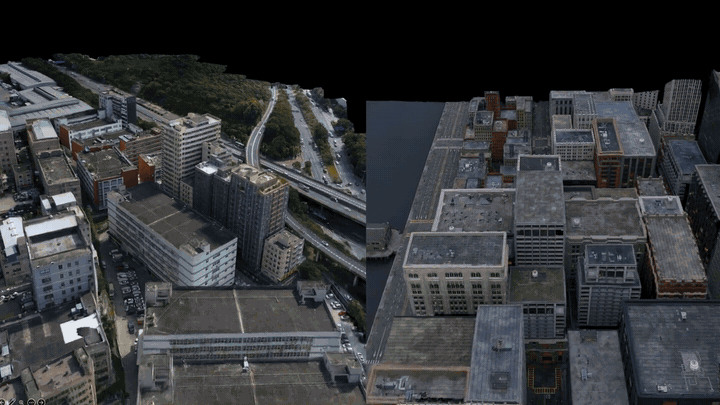
SplatAnything (InfiniSplat v3) reconstructs 3D Gaussian scenes from multiple images across objects, indoor rooms, street scenes, and aerial views, with or without camera poses. Gaussian spacing normalization enables one model to work across arbitrary scenes. It also supports multi-camera rigs and 360° panorama reconstruction.
Code and usage · Installation · Inference guide · Camera and panorama preparation · Citation
InfiniSplat_v3 links to the SplatAnything repository as a Git submodule; its source code is maintained there.
Yongzhen Hu* ·
Hao Yu* ·
Jiawei Wang ·
Xianming Zeng · Jianyun Xu
Xingliang Liu ·
Ruizhen Hu ·
Xiaowei Zhou ·
Hujun Bao ·
Sida Peng†
* Equal contribution. † Corresponding author.

InfiniSplat v2 reconstructs 3D Gaussian scenes from multiple images, with or without camera poses, for novel-view rendering.
Code and usage · Installation · Inference guide · COLMAP guide · 360° panorama → 3DGS
SIGGRAPH Asia 2026 (ACM Transactions on Graphics)

Jiawei Wang* ·
Hao Yu* ·
Yongzhen Hu ·
Xinyi Yang ·
Tao Ni
Xin Zhan ·
Junbo Chen† ·
Xiaowei Zhou ·
Ruizhen Hu ·
Sida Peng†
* Equal contribution. † Corresponding authors.

InfiniSplat v1 reconstructs 3D Gaussian scenes from a single RGB image, optionally guided by LiDAR depth, for novel-view rendering.
Code and usage · Installation · Inference guide
For SplatAnything (v3), initialize the submodule from the repository root, then follow the SplatAnything installation guide:
git submodule update --init InfiniSplat_v3
cd InfiniSplat_v3
The submodule records a specific SplatAnything commit. You can also clone SplatAnything directly to work with its latest code.
For v2, run cd InfiniSplat_v2; for v1, run cd InfiniSplat_v1. Follow the selected version's installation guide. Install each version in its own Python environment; their dependencies and weights differ.
License: Project Registration License (PRL) v1.0
Use solely for academic research, education, evaluation, or personal purposes is free and does not require registration. Research results and publications may be published without registration.
Project use by companies, universities, or other organizations is free but requires prior registration, including non-commercial projects, internal R&D, testing, deployment, and production. Complete and accurate registration automatically grants permission; no approval or fee is required. Register each materially distinct project once.
Project use registration and Word template: Google Forms
V1 and v2 share the project license above. For SplatAnything (v3), refer to the SplatAnything repository for its license and usage terms. Third-party components retain their respective licenses and notices; see v2 component provenance.
See the v1 acknowledgments, v2 acknowledgments, and SplatAnything (v3) acknowledgments.
Reconstruct a 360° panorama with the included
small_empty_house example. Inspired by Enndee.